This thread has been locked.

If you have a related question, please click the "Ask a related question" button in the top right corner. The newly created question will be automatically linked to this question.

TMS320F2800157: TMS320F2800157 and DRV8353 motor control

Part Number: TMS320F2800157
Other Parts Discussed in Thread: LAUNCHXL-F2800157, DRV8353

Tool/software:

Hi,

I'm working on 48V Encoder Motor with DRV8353 and LAUNCHXL-F2800157. I'm using universal motor control project to run the motor with encoder feedback. Currently, I'm trying to run the project in Build Level 2 in ENCODER ESTIMATOR mode. As soon as I set motorVars_M1.flagEnableRunAndIdentify to 1, the moduleOverCurrent fault bit is setting to 1, motor is not even running. I'm sharing screenshots with you regarding the current, voltage sensing parameters. Please check and let me know how I can resolve this issue.

Regards,

Rutuja Gadkar

  • Hi Rutuja,

    Can you try reducing the Acceleration start and max parameters? Also can you collect and share start-up current waveforms using a current probe and trigger with longer capture?

    Best,

    Kevin

  • Hi Kevin,

    Thanks for your reply.

    I'll check start-up current waveform with current probe and share with you. Meanwhile I've tried reducing the acceleration start and max as well, setting it as low as 1 and startup current, I'm setting values between 3 and 6. Still facing the same issue. Can you please suggest what else can I try to solve this issue.

    Regards,

    Rutuja Gadkar.

  • Hi Rutuja,

    A couple other things.

    1. Maybe the align current or settling time is not enough for your motor. See 'USER_MOTOR1_ALIGN_CURRENT_A' define in user_mtr1.h
      1. Checking the current waveforms and watching the motor behavior should give some indication as well.
    2. Verify the V/f profile parameters for your motor:

    Best,

    Kevin

  • Hello Kevin ,

    Thanks for your reply .

    1)

    #define USER_MOTOR1_FORCE_DELTA_A          (0.05f)           // A
    #define USER_MOTOR1_ALIGN_DELTA_A          (0.05f)           // A
    #define USER_MOTOR1_FLUX_CURRENT_A         (2.5f)         // A
    #define USER_MOTOR1_ALIGN_CURRENT_A        (2.0f)        // A
    #define USER_MOTOR1_STARTUP_CURRENT_A      (4.0f)     // A
    #define USER_MOTOR1_TORQUE_CURRENT_A       (3.0f)    // A
    #define USER_MOTOR1_OVER_CURRENT_A            (60.0f)   // A

    2.)Update V/f values like this below


    #define USER_MOTOR1_FREQ_LOW_Hz            (9.0f)           // Hz
    #define USER_MOTOR1_FREQ_HIGH_Hz           (300.0f)         // Hz
    #define USER_MOTOR1_VOLT_MIN_V             (2.0f)           // Volt
    #define USER_MOTOR1_VOLT_MAX_V             (55.0f)

    I am suspecting the motor .because motor specification is 4KW and DRV8353 will support till 1.5KW or lesser .could you please suggest any other gate driver which will support 4KW ?

    Thank you.

    Regards

    Shankar.CP

  • Hi Kevin, 

    Thanks for your response,

    1. I have tried changing the align current along with startup current, increasing it upto 6 align current and startup current upto 10. Still facing module overCurrent. I could see in EPWM trip error DCAEVT1, DCBEVT1, OST setting to 1, when I'm setting enableRunAndIdentifyflag to 1. motorState is MOTOR_STOP_IDLE and it is directly changing to MOTOR_FAULT_STOP as overcurrent flag is getting set.

    2. About the v/f profile parameters it is same as mentioned by . 

    Also, we are suspecting the motor, as it is 4kW motor. Can you please suggest what possible reason it would be for this error to cause and how we can resolve it?

    Regards,

    Rutuja Gadkar.

  • Hi Rutuja,

    I am suspecting the motor .because motor specification is 4KW and DRV8353 will support till 1.5KW or lesser .could you please suggest any other gate driver which will support 4KW ?

    I suggest posting to the DRVx team's forum for their expert's part recommendation for driving your motor.

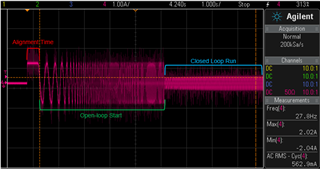
    Can you please collect and share the start-up current waveforms for review? A similar waveform to the below with a wider capture. Of course yours would look different for just open-loop control.

    Best,

    Kevin