This thread has been locked.

If you have a related question, please click the "Ask a related question" button in the top right corner. The newly created question will be automatically linked to this question.

Lab 6b - After running for several hours motor runs poorly

Other Parts Discussed in Thread: TMS320F28069, TMS320F28035

I changed the state of A to B, as the lab says the motor will now move CC to CCW and did so for an hour or so.

The the motor generated a grinding while running. Which has progressively gotten worse.

I have not changed any values, and the motor is new.

I a value changing I might not have noticed? I rebooted and yesterday it cleared up, and was fine this morning.

This afternoon, grinding and sort of jumping as in moves.

Could it be running in lab 6B to long?

Any suggestions?

Thanks,

David

  • David,

    After running for hours did the motor start to heat up?  Were the PWMs ever shut off during that time?

  • Yes, I finally checked and the motor was rather warm. I'm not sure where I would have turned the PWM's off from, so I don't know exactly how to answer that question.

     I created a GUI to turn on gMotorVars.Flag_enableSys and gMotorVars.Flag_Run_Identify or set to true, then I enable

    gMotorVars.SpinTAC.VelPlanRun.

    DAvid

  • David,

    What I bet has happened is that the motor has heated up enough to where the resistance of the motor has changed significantly.  When this happens the sensorless estimator has difficulty estimating the angle of the motor and the control will suffer this will be worse at lower motor speeds.

    If you look at lab 7 this is an example of using a feature called RsOnline which will continuously estimate the resistance of the motor and will compensate for that temperature increase.

  • Ok, Thanks Adam.

    I will load that and check it out. I removed the motor and chilled it down in the frig. Connected it and still no changes while cool.

    Get back at it shortly. Let me load lab 7.

    Thanks,

    David

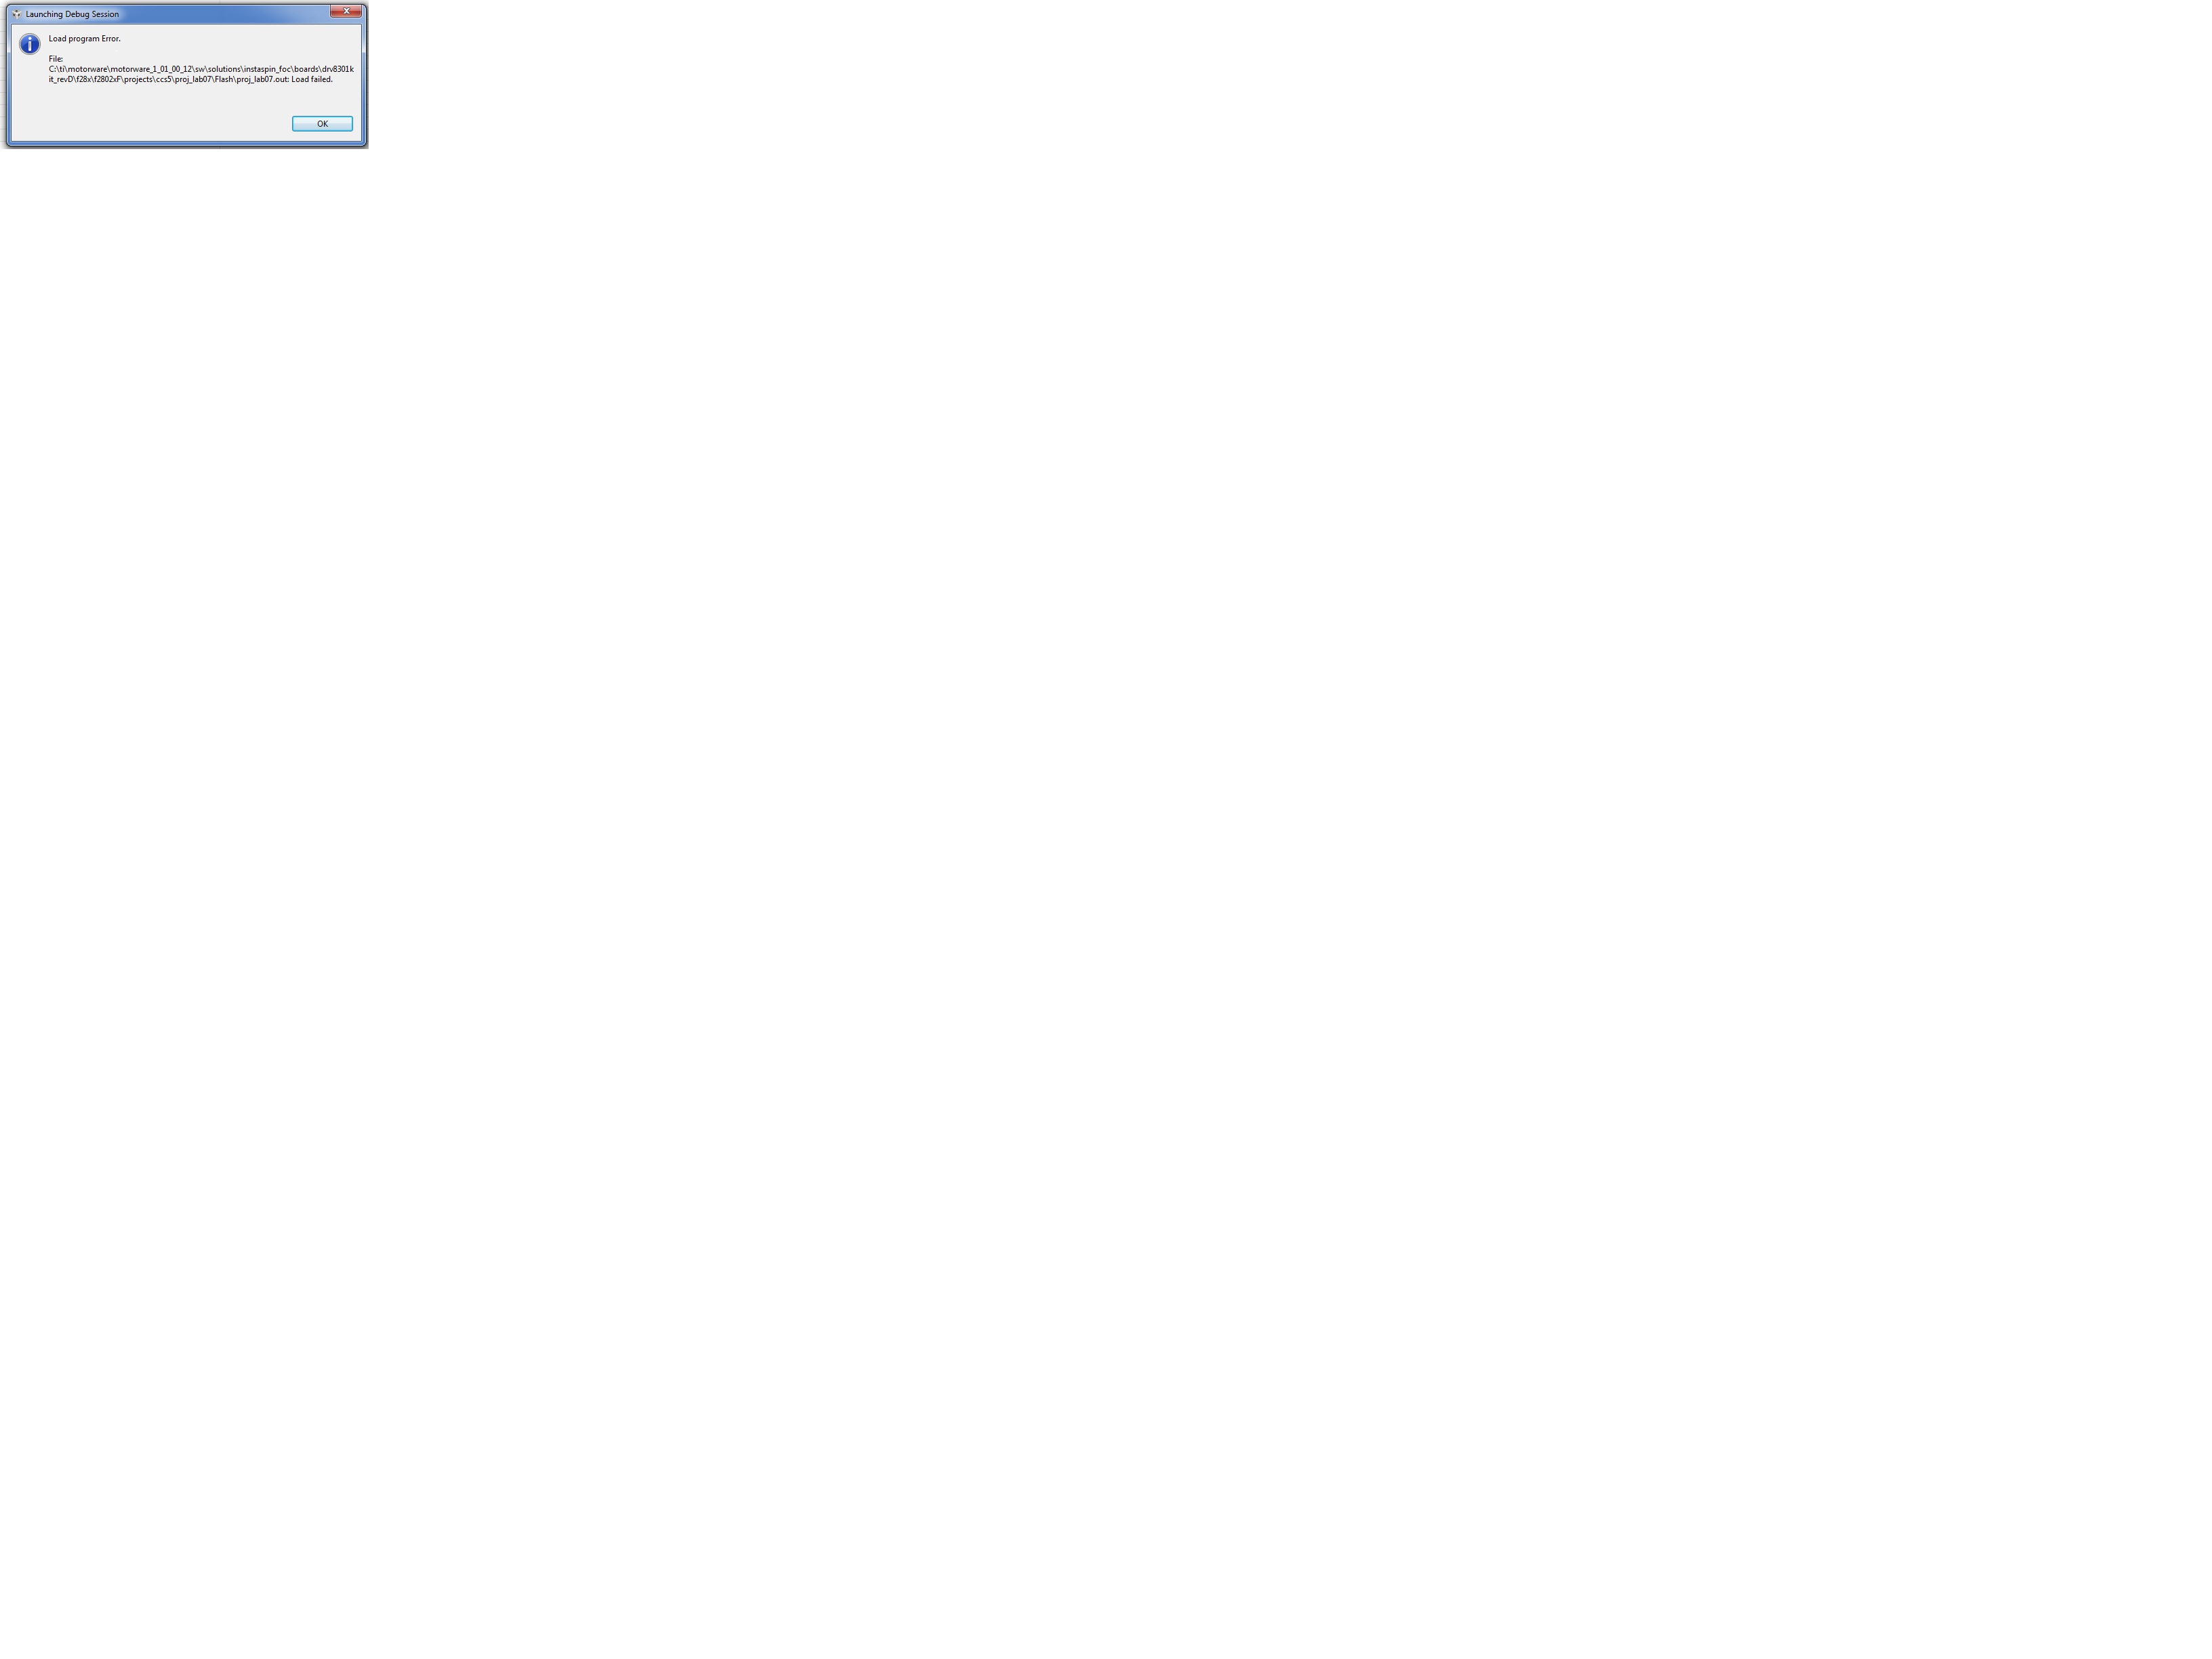
  • Well that didn't go well. I erased the chip, but I get this error upon download (programming).

    Got any suggestions?

    Thanks,

    David

  • David,

    I would recommend that you power cycle the board and unplug and reconnect the USB cable.  Other thing to check is the switch used to automatically boot from flash needs to be returned to the default position to connect the USB debugger.

  • Adam,

    Ok, I did all the above, but I didn't change any switches in the first place. All I did is run lab6b.

    However, I did find the problem. The configured device (TMS320F28035), does not match the detected device (TMS320F28069) I double checked the file and I suppose I loaded the wrong one. The motor and I went over lab 7 and I saw where Rs changed. Question: should I have updated my user.h file here?

    So I finished lab 7 and repeated lab6b, and it still runs as rough as a cob.

    I am really interested here so please offer suggestions. I learn from every one of them. I'm getting to move around the labs and spot some of my own errors while learning.

    Thanks,

    David

  • Ok Adam,

    I going over and over the forums, the labs trying to find an answer. Got lots of notes.

    Running lab 6b. So while it is vibrating I fear it may fall off the table, even tho it is between to large blocks of metal.

    So I a little frustrated, smack it back toward the middle of the table so it is less likely to fall off. Lo and behold,

    the vibration stopped, runs fine now.

    I want to go back home soooo.... bad.....

    Anyhow, would you be so kind as to point me in the right direction for a project I am trying to do.?

    Perhaps what lab I need to look at next, or use. I would like to control the motor windshield like fashion.

    Back and forth, to monitor position using an encoder, would I place that code in the project lab.c file or elsewhere?

    Anything you would be so kind as to give me, boy, would I be thankful.

    Sincerely,

    David

  • David,

    In order to use the RsOnLine software you would need to integrate the code from that lab into the 06b lab to make use of the RsOnLine code with lab 06b.  

    The RsOnLine code is use to mitigate the case where the motor is heating up.  

    When the motor is cold it still runs rough?  If this is the case I don't think the RsOnLine will resolve your issues.

    Has anything changed in between your success previously and now?

  • David,

    Has the inertia for this setup changed?  If the inertia is changing more than 8x it needs to be re-estimated.

    Lab 13c will let you use a Plan to setup point to point position moves.  I would recommend that prior to lab 13c you start with Lab 13a & Lab 13b.  

  • Thank you Adam,

    Back to 13 it is.

    David

  • Well the motor runs rough both cold and warm, never gets hot.

    I was afraid that it might jump off the desk so I quickly smacked it back a little.....Then it ran perfectly for a while.

    Now it always runs rough. No, :) I didn't smack it any more. (felt so guilty after the first time) :)

    Over the holiday weekend I was looking over the user.h file. The engineer told me that he thought one had an encoder rate of 1000 and the other (twin) motor) might be 2000 encoder rate. My user.h file has 2000, which is what I was first told it was. So I am going to change that and see what happens. The motors are brand new, and TI has borrowed one to evaluate, but I have not heard from them in a while. My user.h file is a match for the one they came up with for the twin. Since I just found out about the encoder rates maybe being different I think this may be worth a try.

    David

  • Ok, That did not work well.  Changed encoder lines to 1000 from 2000, motor power supply lines slowly heating up.

    Will change back to 1000 and see what happens.

    David

  • Back to 1000. Motor doesn't turn at all. Changed motor bandwidth to 2 from one. Motor supply wires warming up again.

    Will change bandwidth back to 1 and go back to lab 6b and see what happens.

    David

  • Went back to Lab 6b. Wires don't warm up, but will not spin in either direction. It once did in lab6b. I checked the shaft to see if it moved freely, it does. So I am guessing here that a critical parameter has changed. Any suggestions on what to look for or do next?

    Thanks,

    David

  • David,

    If you can't run the motor sensorlessly,  it sounds like you are having some kind of hardware related issue.  I would check the motor phase wiring to ensure that it is still connected.  Were any parameters changed in the user.h file from when it was working?  Is there any damage to the evaluation kit?  Do you have a second evaluation kit you can try?

  • Adam,

    Thank you for your reply, I learn something every time.

    I "double checked" the motor lines. The thought about the hardware having some issues had occurred to me before with other problems I have been having. We will have a project progress meeting today and I will address the issue of buying another board today. I am currently going over the user.h file line by line for changed values, corruption, etc. I am using a "gold" standard provided by TI. I'll get right back to you as soon as I have some objective answers.

    Thanks again for staying with me on this.

    DAvid

  • Just an update, I have not found any changes in the user.h file.

    We have another 8301 board on order.

    David

  • Adam,

    Well, good new, bad news. The new motor came in first, I wanted to contact you sooner, and it ran perfect.

    So it seems it was the motor all this time. That's the good news.

    The bad news is the mech. eng. who was my boss,  feels like I don't know what I am doing because it took so long and....well I don't work there anymore, so I won't be bothering you anymore with lab questions.(you may consider that the good news Ha Ha  Ha)

    Thanks to you and Chris. You guys really helped me.  Take care of yourselves.

    David