Part Number: MOTORWARE
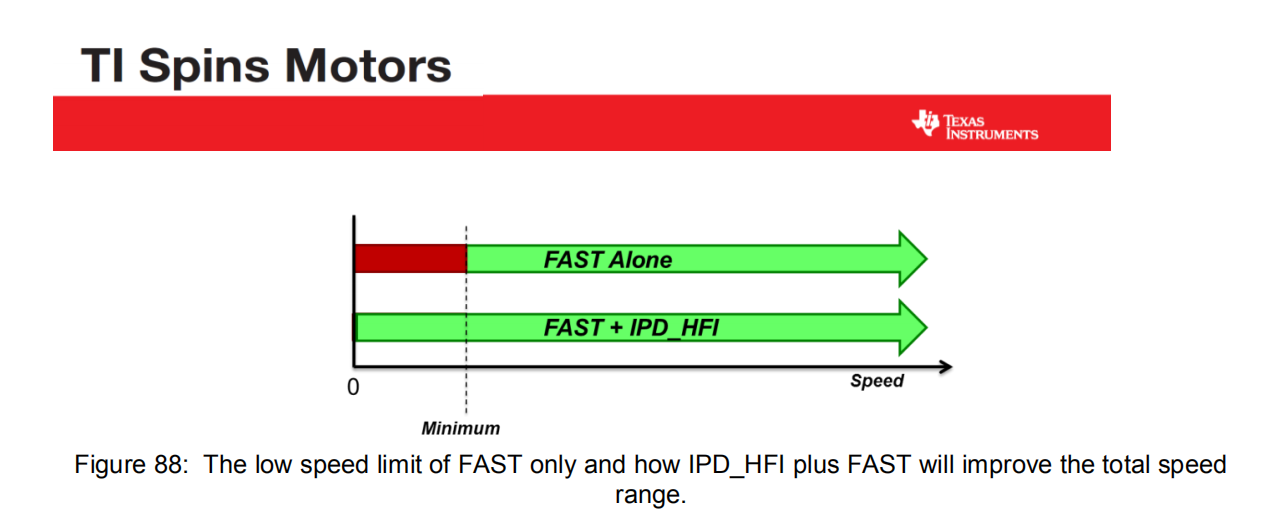
As shown in the topic,In Motorware, the routine PROJ_LAB21 shows low speed and zero speed using IPD_HFI, and medium speed is switched to FAST observer through AFSEL, but other Motorware routines do not use IPD_HFI, only use FAST observer, how does it achieve low speed and zero speed Angle estimation?In addition, the Instaspin_labs documentation also states that FAST observer Angle estimation does not cover low speed and zero speed, which is very strange. Please clarify the confusion, thank you!