This thread has been locked.

If you have a related question, please click the "Ask a related question" button in the top right corner. The newly created question will be automatically linked to this question.

DRV8308: Control loop

Part Number: DRV8308

Hi Experts, 

I have few questions on the DRV8308 

  1. May I know if there is current closed loop built in the driver? If yes, which parameter is for user to adjust based on the motor?
  2. Is it possible to share the control diagram of the current and/or velocity loop? It may help us to locate the parameters for the tuning.


Best Regards

  • Xiaolan,

    Thanks for posting on the Motor Drives Forum.

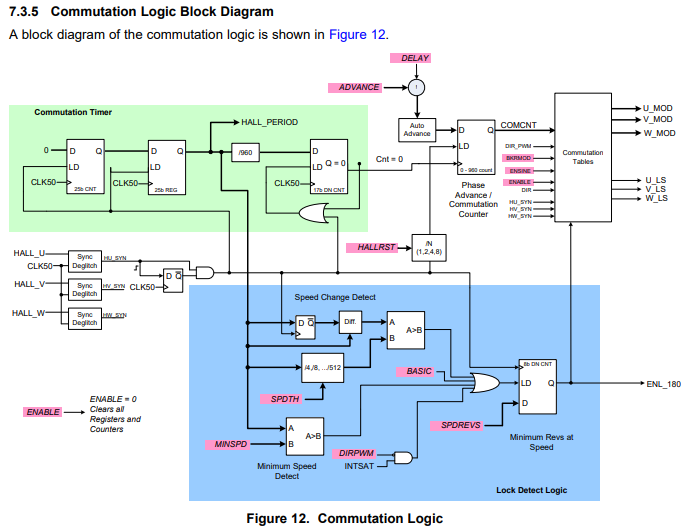
    There is no closed loop current control built into the device. The only closed loop control available uses the speed, FG, and lock to control the commutation and similar. This is documented in the datasheet as follows:

    Tuning will involve the pink signals and registers as seen above, they are described in the datasheet in length.

    Regards,

    -Adam

  • Hi Adam,

    Thanks.

    May I know if there are two control steps as following?


    During speed ramp up (Acceleration stage), the speed is open loop with the gain SPEED.


    Qn 1. How to determine SPEED? For example, the target speed is 1200RPM, the acceleration time is 100msec, assume that the 2nd order profile used, so the expected acceleration is 200Rev/s^2  (acc=speed/time), what SPEED should be set?


    Qn 2. Is there any speed command profile built-in?


    Qn 3. How does the driver determine the constant speed has been reached?


    During constant speed, (Acceleration is zero), the speed is closed loop.


    Qn 4. Is AG_SETPT the target speed which user sets?


    Qn 5: Is LOOPGAIN a proportion gain of the speed error (Target speed – actual speed which feedback from Hall sensor)?


    Qn 6: Is ADVANCE for the compensation of the zero crossing of commutation?


    Qn 7: Could you explain more on the effect of AUTOADV? Is AA_SETPT the target speed which user sets as AG_SETPT?


    Qn 8: Is IDRIVE a feed forward of current? Which can be used to compensate the static friction of moving parts?


    Qn 9: Is SPDGAIN as an integration gain of Speed loop?


    Qn 10: Is it possible to explain more on Figure 19 Integrator and Filters?


    Best Regards

    Xiaolan

  • Xiaolan,

    1/2. There is no speed command profile or ramp rate, this will need to be implemented in your control software or MCU.

    3. Depending on the state of FGSEL, the DRV8308 will either use the FGIN signal or HALL inputs to check for a constant speed, once the variation of the chosen input is below a certain threshold, the driver assumes a constant speed has been reached.

    4/5/6/7/9. Please see section "4.1 Key Registers" of the DRV8308 User's Guide here: http://www.ti.com/lit/ug/slvua41f/slvua41f.pdf

    8. IDRIVE is simply the current control for the FET gates which in turn controls the slew rate of the output. This has nothing to do with the control loop or any motor physics.

    10. This is described in the previous section in the datasheet.

    Regards,

    -Adam

  • Hi Adam,

    I have read through the datasheet and user guide, but still not clear on the Qn 4,5,6,7,9,10. Is there any application notes or example to share?

    Thanks

    Best Regards

    Xiaolan