Part Number: MSP430FR4133
Hello,
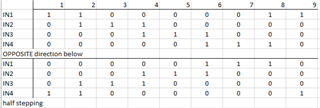
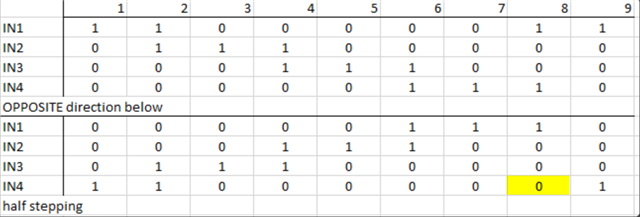
I have been trying to control a stepper motor (BYJ48) with a ULN2003 driver for the past several days to no avail, the stepper motor moves but extremely slowly and vibrates back and forths, here is my very simple code:
void main(void)
{
    WDTCTL = WDTPW | WDTHOLD; // Stop WDT
    // Stepper Pin 1 = GPIO_PIN3, Pin2 = GPIO_PIN4, etc.
    GPIO_setAsOutputPin(GPIO_PORT_P1, GPIO_PIN3 | GPIO_PIN4 | GPIO_PIN5 | GPIO_PIN6);

    while(1)
    {
      for(int i = 0; i < 12; i++)
      {
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
      }

      GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN3);
      GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
      GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
      GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
      __delay_cycles(1000);

      for(int j = 0; j < 12; j++)
      {
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
      }
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN3);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN4);
        GPIO_setOutputLowOnPin(GPIO_PORT_P1, GPIO_PIN5);
        GPIO_setOutputHighOnPin(GPIO_PORT_P1, GPIO_PIN6);
        __delay_cycles(1000);
    };
    // __bis_SR_register(LPM0_bits); // Enter LPM0
}
Where GPIO_PIN3 is IN1, GPIO_PIN4 = IN2, GPIO_PIN5 = IN3, GPIO_PIN6 = IN4.
I am also using an external supply to power the motor.
I simply just want the stepper motor to rotate continuously 360 degrees. I am following this video for reference... https://www.electronicwings.com/ti-launchpad/stepper-motor-interfacing-with-msp-exp430g2-ti-launchpad
It's Arduino based but the code is equivalent.
Help is much appreciated Thanks