A related question is a question created from another question. When the related question is created, it will be automatically linked to the original question.
If you have a related question, please click the "Ask a related question" button in the top right corner. The newly created question will be automatically linked to this question.
What function would you like to achieve with this device?
If you connect the device in single supply configuration, these are your limitations:
INPUT:
VCM or average voltage seen at inputs must be greater than -.1V when V- = GND. VCM must also be less than V+-3V for linear operation.
This means if you supply the device with +30V for V+, and GND for V-, your worst case valid VCM range would be -.1V to 27V.
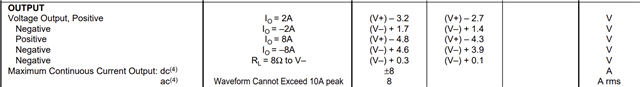
OUTPUT
Output swing depends on output current, but we can use this table to estimate swing to rail performance:
If you can provide more details for what you would like to accomplish, I can help with designing a circuit for you.
Remember also, most all applications using the OPA549 will require a relatively large external heatsink due to the high power dissipation of this device. I can help with picking a heatsink once we hash out the project requirements here.
I will use OPA549 as a power amplifier instead of old type power amplifier for single supply servo motor driver. It will work 27 Vdc power supply and servo motor can draw 6 to 10A current. I thought the OPA549 is sufficient to drive it. If I'm wrong, I'd appreciate it if you could provide an alternative driver circuit.
Hey, thanks for the additional details, this is very helpful to me.
Either the OPA549 or the OPA541 would be suitable to this application.
Something simple like this can work well:
Do you know your servo coil impedance? It will also be important to consider total power dissipation here. 10A will be lots of power dissipation in the output stage.
The OPA549 for example will only do 10A pulsed. Worst case, it may be beneficial to use two amplifiers.
Here is a curve which defines the output current relative to VDS across the output stage transistors:
Thank you for feedbacks. I don't know the coil impedance. The old servo amplifier is EM1803A. And there is no neative voltage on the system. I can use only +24 Vdc and ground. The output power of EM1803a is 300W but i think the motor can not draw more than 8 A. The motor steps may be too low. And the system may draw a maximum of 10A. Do you have an alternative solution for this situation?
I was able to find an old snippet of information on this EM1803A, it does seem like OPA549 will be able to do some of what this amplifier was capable of doing. I am still a bit cautious with the SOA requirements here. 8A continuous is possible, but thermals and output voltage are important. Do you have a schematic for the original amp?
We may benefit from using two of these OPA549 devices in parallel for support up to 20A load current. This will consequently make the SOA curve wider. operation.
What feedback signal comes from the servo controller? I assume this is used to drive the power amp, and consequently manipulate the position of the rotor.
The schematics of the circuit is on the below. There are two modules because of two motors . As you see, the amplifier has got characteristic of current control. Can we provide this feature with OPA549?
In this circuit i could not find the gain of the amplifier. . How can we create Gimbal Drive Hi and gimbal Drive Lo signals for OPA549 like as EM1803 ? And my other problemis how can we also create a feedback input signal and which pin will i use for this sinal? I think pin 8 is suitable for feedback input. However, in the original servo amplifier circuit, as soon as the device is turned on, the servo amplifiers bring the gimbal to its center position. I haven't figured out how to do this with the OPA549 yet.
I couldn't probed any signal for the motor and i don't know anything about motor. The only thing I know about a motor is its driver. I noticed something in the schematic i sent you before. The driver has both 27V and -15V, but the maximum current from -15V can deliver is 1.5A. And these amplifier converts the control voltage into proportional currents. I'll try to measure these signals. Is there anything else you'd recommend?
You are correct regarding the schematic. This is a very strange device to me, but it does look like the datasheet recommends +28V+-4V for V+ and -15V+-2V for negative supply. This makes +27V and -15V a valid operating range for the part.
I am also interested in understanding how the current drive is functioning with just 1.5A limit on the V- rail.
I take it the motor has the negative terminal grounded since we have one motor driver per motor. Surely these motor drivers can rotate backwards, right? If we were only driving one direction, or there was only significant mechanical loading in one direction, then it would make sense for V+ to have higher current requirements than the V- rail.
Yeah, I think signals, especially being output and input signals will be helpful here.
The E1308 datasheet is a bit short, but it has offered some help in understanding how this driver may be operating.
I think that i should provide +27V and -15V to power the OPA549 instead of this driver. However, I thi,nk that OPA549 will work unbalanced, right?
Existing motor drivers can operate both forward and reverse. One thing I don't understand that the low current at negative voltage means they don't need as much current at positive voltage, so why use such a powerful servo amplifier? I'd appreciate it if you could share with me your thoughts on how the current driver works.
Yes, the OPA549 will run on an unbalanced supply rail without issue.
There are two effects here to think of.
1. output swing limits
2. current limiting (either from the rail or from the device hitting IOUT max)
If the impedance of the motor windings are excessively high, we would presumably run out of output drive. I can only imagine our OPA549 is a better performing device compared to the original amplifier used, but there is still some risk.
If the V- rail is truly limited to supplying just 1.5A, then we will likely see some non-desired performance in driving the servo if the motor load ever wanted more than 1.5A.
As I understand, the servo is a DC motor, which has speed correlate with motor voltage.
Here is a simple simulation which shows the performance with an impedance I may expect to see out of a motor:
Here, we are not having issues with output swing, though we are also using an ideal power rail.
Here is the same simulation with a power limit on the V- side.
I am not completely sure why the 1.5A limit would exist, this feels like it would limit functionality for this system. You are correct on the other way of interpreting, maybe this means that the servo driver on the positive side is way overkill for what is needed. Still a very strange design to me. Maybe signals will tell us more.
Thank you for sharing. İn schematibs, -15V COMPUTER power line comes from 1,5A PSU, system has g ot also +15V PSU, both of them are used for generally OPAMPs. For this reason i didn't understand that positive and neative PSUs current limits are so different. The EM1803's datasheet states that its 300W output voltage gain is 20. I'll try to provide this gain in the new circuit. I'll share the measurement results with you on the current device.
Thanks for looking into this for me. I agree, the power difference is strange to me. I am wondering if the servo does not require as much power as the EM1803 is capable of supplying.
Any idea the size of the servo? Some motors have a little data plate that helps offer some info as for the specs.
If not, maybe it is safe to assume that the implementation is not utilizing significant power for sinking current. Since this is not a case where one direction is more powerful than the other, I am inclined to believe that the amplifier does not actually need to be 300W.