TL081H: Simulating Loop Gain with basic TL081H opamp based Linear Power Supply

Part Number: TL081H

I'm trying to simulate a very standard TL081H based Linear Power Supply Topology in TI-Tina.

I'm modifying the spice files from TIDU026 Single Opamp Slew Limiter - Tim Green.  

I've watched a few on-line videos. I've also been looking at the SBOA626 Opamp Stability Theory and Compensation Method by Art kay and Collin Wells. None of these venture outside basic opamp simulation. 

 
My Linear Power Supply simulations are showing waveforms that don't behave as I would expect.

The AOL curve isn't continuous. It flattens at 0dB then a few decades late continues into the -dB area.

1/beta seems to merge with AOL - rather than cross-over it.

Repositioning the Vout and the Voa_U1 tabs gives different results. Possibly I haved used the incorrect locations for spice work.

There are two files. 
One is the desired circuit - PNP pass transistor version. 
The other is the simplest NPN variation. 

Both give strange results.  

Might anyone know where I am going wrong?

Thanks

Peter

LPS Loop Gain Eval NPN.TSC

 LPS Loop Gain Eval PNP.TSC 

  • Hi Peter,

    From the amplifier's perspective, this circuit has two feedback paths, so checking the stability in simulation is a little different. To break the loop complete Also, I noticed that the Vee voltage wasn't connected to the V- pin of the opamp.

    This document explains how to check the stability of this topology at a high level (on page 5), and I've moved your schematic around a bit to make it easier to analyze. Starting with the PNP version, where I broke the feedback loop at the inverting input of the amplifier (which opens both feedback loops). To include the effects of the input capacitance when the loop is broken at the inverting input, the total input capacitance of the amplifier will need to be added manually before the inductor (which is why I added Cin below):

    At DC, the circuit is behaving normally:

    The loop gain of the circuit with respect to the amplifier is VFB(s) / VM(s), but given that VM is the test signal, LoopGain = VFB. 

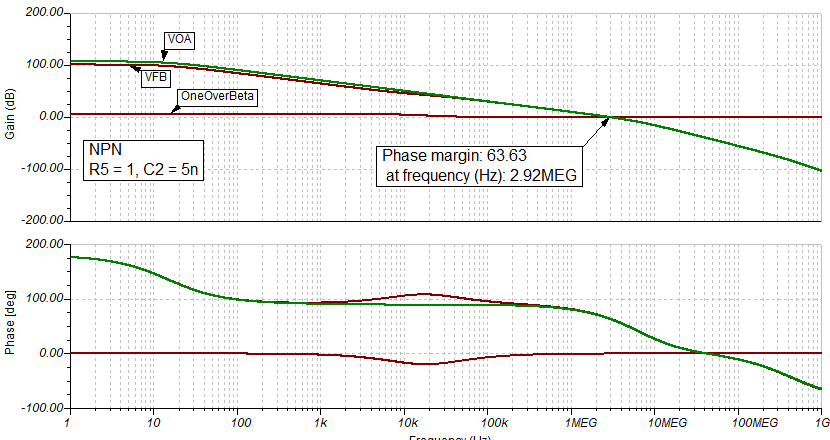
    Notice the rapid phase shift of 1/Beta around 1MHz, which is not ideal. Adjusting the values of R5 and C2 will change the 1/Beta curve and smooth this out. 

    For the NPN version, I broke the loop in the same place:

    You can find the modified TINA files below. Let me know if you would like help adjusting the component values.

    LPS Loop Gain Eval PNP - Modified.TSCLPS Loop Gain Eval NPN - Modified.TSC

    Also, I broke the loop at both inputs for both circuits as well, and got the same result. This method is generally going to provide the most accurate results, but setting the circuit up is a bit more involved.

    LPS Loop Gain Eval PNP - Modified Alt.TSCLPS Loop Gain Eval NPN - Modified Alt.TSC

    Best Regards,

    Alex Curtis

  • I'm unable to add *.tsc files to my response. Is there another way to do it?

    Peter

  • LPS Pos Regulator - Loop Gain Eval.zip

    Hi Alex,

    Thank you for your response to my question.


    From your modifications done to the Sim files, I created four Linear Power Supply simulation circuits.

    Two for Positive Voltage. A Low-Drop-Out version and a “standard” version

    Two for negative Voltage. A Low-Drop-Out version and a “standard” version.

    You made an offer to determine the optimal R & C values for these circuits. I’d appreciate you doing that. Firstly, I’d like to see what sort of combinations are appropriate. Additionally, I’m sure that others would like to see what you do as well.


    Both (non LDO) Regulators appear to have approx 60-degree phase margin and look good.

    On the LDO versions, the phase swing was severe. I added Miller Capacitance across the PASS transistor which smoothed out the phase considerably.

    Many a time, while refining these circuits, I’d get an “Access Violation” message. I could never determine what it meant.


    Your comments and the corrected sim files have been very valuable for me.

    For my (and others) education, why do you prefer to draw the simulation circuit “backwards”?


    Finally,

    I got tremendous value out of Tim Green’s “Single Opamp Slew Rate Limiter” – which included both design information and sim files.

    Possibly you might consider tidying up these sim files and packaging it with some design information. Then add it toTI’s Opamp Stability and Compensation resources for others to benefit from.


    Best Regards,

    Peter Baxter  

  • Hi Peter,

    I'm glad to hear that my comments have been helpful. I'll need a bit more time to answer your questions about choosing the values of the compensation components, as the frequency responses here are fairly complex, so I'm considering splitting the feedback network into a multiple 1/Beta curves. Also, I just wanted to say that these updated TINA files you provided in the ZIP file are very well put together and easy to work with, which is greatly appreciated. Slight smile

    Regarding your other questions/comments:

    • I mirrored the amplifier in the TINA files to better match this schematic in the literature I linked in my first response. Mostly just a stylistic choice on my part.
    • The "Access Violation" error message is likely a bug within TINA, and unfortunately I'm not sure what causes this error. Usually restarting TINA helps make this error go away in my own experience.

    I'll follow up within 48 hours. In the meantime, feel free to ask any follow up questions.

    Lastly, 

  • Hi Peter,

    I don't have an answer for you just yet as I'm still discussing with my team. Please allow an additional business day for us to work on this, and I appreciate your patience.

    Kind Regards,

    Alex Curtis

  • Hi Alex,

    Please take your time - as I am in no hurry. I have plenty else to do.

    Best Regards,

    Peter Baxter

  • Hi Peter,

    An update on our progress so far. We broke the circuit down into a few different layers to make it simpler to see how each element impacts the overall response. First, we looked at the effect of just the outer loop with the amplifier removed entirely. This shows the effect of the miller cap.

    The Miller cap shifts the first pole to approximately 1.36kHz.

    Positivie_LDO_Example_bipolar_only_FIXED.TSC

    Then, looking at the inner part of the loop with amplifier:

    Positivie_LDO_Example_amp_only.TSC

    Then combining both loops together:

    Positivie_LDO_Example_both.TSC

    Below is the overall transient response.

    Positivie_LDO_Example_both_transient.TSC

    A few takeaways so far:

    1. The high frequency results are very complex and ultimately aren't very useful to stabilize the circuit given that a rolloff at a low frequency is usually more desirable. 
    2. We switched to the newer TL07H model instead of the TL07 model to reflect the new device's performance.
    3. This circuit is difficult to analyze, and although the result is stable, I'll need to go through the AC analysis of each portion in more detail to give a better picture of which interactions are the most significant, particularly when it comes to how the output impedance of the amplifier is interacting with the miller cap and load resistor. Update: see the corrected plot of the response of the outer loop with the Miller cap.
    4. Because of the presence of gain in the feedback loop, phase margin will only tell you so part of the story, so there might be some Nyquist plots headed your way soon.

    Best Regards,

    Alex Curtis

  • Hi Alex,

    My Apologies for not getting back to you. I got distracted by other technical work.

    You left a cryptic comment at the end of your last response which actually had me thinking I'd get the final bit of wisdom/knowledge - in a following email.

    "so there might be some Nyquist plots headed your way soon."

    Yes, I was hoping that it would come through as I am learning from what you have given me. You used a far higher Cf value (56n), than I was expecting.

    If you can do the Nyquist plots - I'd be very interested.

    Regards,

    Peter Baxter.

  • Hi Peter,

    I appreciate the follow up, I had meant to return to this earlier but had some other priorities to take care of since my last post.

    I've spent a few more hours on the stability simulation of the full circuit, and checking the stability with Nyquist would be more involved than I initially thought. That being said, I might be able to find a way to generate the plots by pulling the AC responses into MATLAB, but I would need more time to go down that route. Ultimately the magnitude responses aren't too strange (for example, the magnitude response of the loop only crosses 0dB once), so they may not be too valuable here, but I can explore this more if you're interested.

    The Nyquist plots aside, I think the bode plots are still useful for illustrating how the inner compensation values change the overall response. Regarding why the cap value was set to 56nF, this value depends on where the zero frequency needs to occur to bump up the phase.

    I set the inner components as Control Objects (Analysis -> Select Control Object) to step through different component values to illustrate this. 

    Below, I zoomed in on the 1k-10MHz range to illustrate how the phase response changes due to the compensation.

    Zooming in further to where everything crosses 0dB, these are the phase margins:

    The best phase margin of these combinations was with R3 = 200Ohm and C8 = 50nF. You can adjust further using the simulation below:  

    Positive_LDO_Example_both_V2.TSC

    Best Regards,

    Alex Curtis

  • Hi Alex,

    I'm finding this very interesting. 

    However, this is the time to close this thread - as you've given me very useful information that I can work with.

    Nyquist Plots are involved and I don't feel you should be spending any more time on this. 

    Once again, thank you for a very educational response.

    Best Regards,

    Peter Baxter