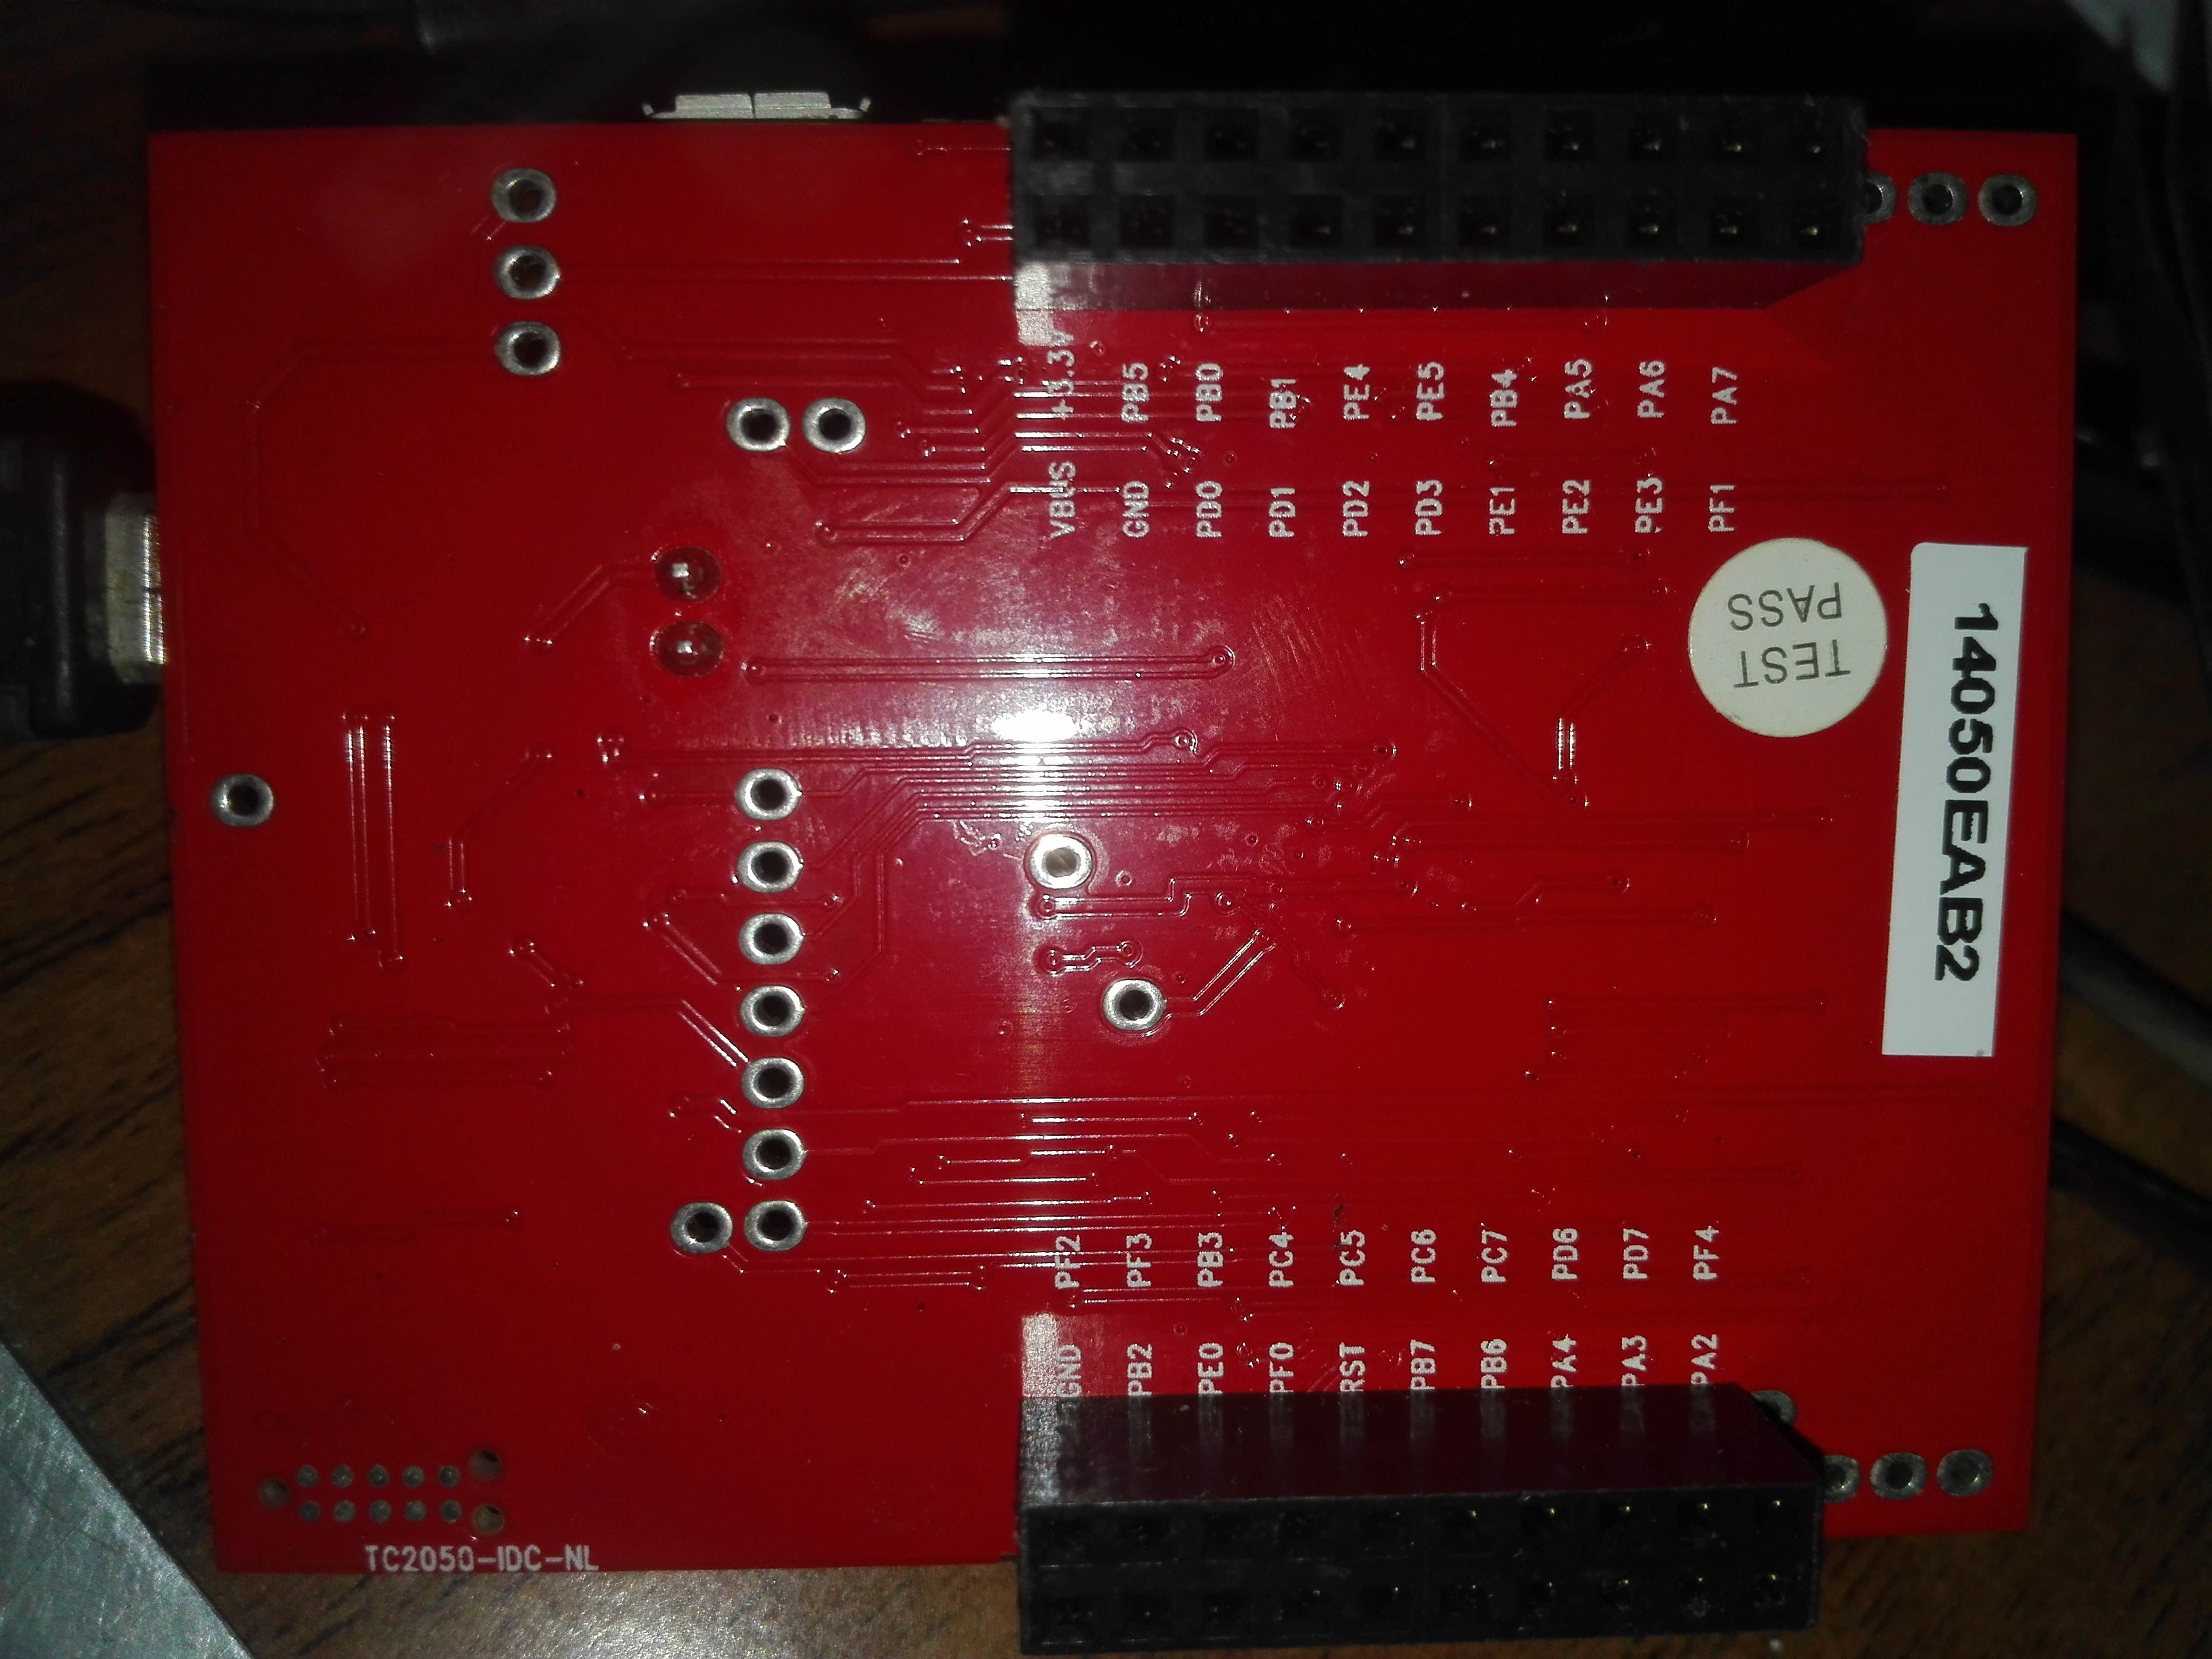
Other Parts Discussed in Thread: EK-TM4C123GXL
i wos working on creating a spwm using pb6 and pb7 but suddenly now whatever i do "even if i'm running an empty code or trying to set the to 0" the pins are always high even if i paused in the debugging mode
i could't find any direct short between the 3.3v and the pins
that's the code i used
#include <stdbool.h>
#include <stdint.h>
#include "inc/hw_ints.h"
#include "inc/hw_memmap.h"
#include "driverlib/gpio.h"
#include "driverlib/interrupt.h"
#include "driverlib/pin_map.h"
#include "driverlib/pwm.h"
#include "driverlib/sysctl.h"
uint16_t sinus[]={1,2,5,7,10,12,15,17,19,22,24,27,30,32,34,37,39,42,
                  44,47,49,52,54,57,59,61,64,66,69,71,73,76,78,80,83,85,88,90,92,94,97,99,
                  101,103,106,108,110,113,115,117,119,121,124,126,128,130,132,134,136,138,140,142,144,146,
                  148,150,152,154,156,158,160,162,164,166,168,169,171,173,175,177,178,180,182,184,185,187,188,190,192,193,
                  195,196,198,199,201,202,204,205,207,208,209,211,212,213,215,216,217,219,220,221,222,223,224,225,226,227,
                  228,229,230,231,232,233,234,235,236,237,237,238,239,240,240,241,242,242,243,243,244,244,245,245,246,246,
                  247,247,247,248,248,248,248,249,249,249,249,249,255,255,255,255,249,249,249,249,249,248,
                  248,248,248,247,247,247,246,246,245,245,244,244,243,243,242,242,241,240,240,239,238,237,237,236,235,234,
                  233,232,231,230,229,228,227,226,225,224,223,222,221,220,219,217,216,215,213,212,211,209,208,207,205,204,
                  202,201,199,198,196,195,193,192,190,188,187,185,184,182,180,178,177,175,173,171,169,168,166,164,162,160,
                  158,156,154,152,150,148,146,144,142,140,138,136,134,132,130,128,126,124,121,119,117,115,113,110,108,106,
                  103,101,99,97,94,92,90,88,85,83,80,78,76,73,71,69,66,64,61,59,57,54,52,49,47,44,42,39,37,34,32,30,
                  27,24,22,19,17,15,12,10,7,5,2,1};
int x=0,en=true;
long map(long , long , long , long , long );

void
PWM0IntHandler(void)
{

    PWMGenIntClear(PWM0_BASE, PWM_GEN_0, PWM_INT_CNT_LOAD);

    if(++x>311){x=0; en=!en;}
    if(en==true){
    PWMPulseWidthSet(PWM0_BASE, PWM_OUT_1, 0);

    PWMPulseWidthSet(PWM0_BASE, PWM_OUT_0, map(sinus[x],1,255,0,535));
    }
    else
    {
    PWMPulseWidthSet(PWM0_BASE, PWM_OUT_0, 0);

    PWMPulseWidthSet(PWM0_BASE, PWM_OUT_1, map(sinus[x],1,255,0,535));
    }
}


int
main(void)
    {

    SysCtlClockSet(SYSCTL_SYSDIV_1 | SYSCTL_USE_OSC | SYSCTL_OSC_MAIN |
                   SYSCTL_XTAL_16MHZ);
    SysCtlPWMClockSet(SYSCTL_PWMDIV_1);


    SysCtlPeripheralEnable(SYSCTL_PERIPH_PWM0);

    SysCtlPeripheralEnable(SYSCTL_PERIPH_GPIOB);

    GPIOPinConfigure(GPIO_PB6_M0PWM0);
    GPIOPinConfigure(GPIO_PB7_M0PWM1);

    GPIOPinTypePWM(GPIO_PORTB_BASE, GPIO_PIN_6);
    GPIOPinTypePWM(GPIO_PORTB_BASE, GPIO_PIN_7);

    PWMGenConfigure(PWM0_BASE, PWM_GEN_0,
                    PWM_GEN_MODE_DOWN | PWM_GEN_MODE_NO_SYNC);
    // equation: N = (1 / f) * SysClk.
    PWMGenPeriodSet(PWM0_BASE, PWM_GEN_0, 535);

    PWMPulseWidthSet(PWM0_BASE, PWM_OUT_0, 64);
    PWMPulseWidthSet(PWM0_BASE, PWM_OUT_1, 66);
    PWMOutputInvert(PWM0_BASE, PWM_OUT_0_BIT|PWM_OUT_1_BIT, true);

    IntMasterEnable();

    PWMIntEnable(PWM0_BASE, PWM_INT_GEN_0);

    PWMGenIntTrigEnable(PWM0_BASE, PWM_GEN_0, PWM_INT_CNT_LOAD);

    IntEnable(INT_PWM0_0);
    IntEnable(INT_PWM0_1);
    PWMOutputState(PWM0_BASE, PWM_OUT_0_BIT | PWM_OUT_1_BIT, true);
    PWMGenEnable(PWM0_BASE, PWM_GEN_0);
    while(1)
    {
    }


}
long map(long x, long in_min, long in_max, long out_min, long out_max)
{
  return (x - in_min) * (out_max - out_min) / (in_max - in_min) + out_min;
}
thanks